Preparing your experience
Skip to content
SELECTED ENGINEERING WORKTECHXPERT / PORTFOLIO

Engineering.
Made tangible.

Intelligent systems. Physical prototypes.
Software that brings them together.

Explore TechXpert’s engineering portfolio, from assistive intelligence and robotics to connected products.

Explore the work
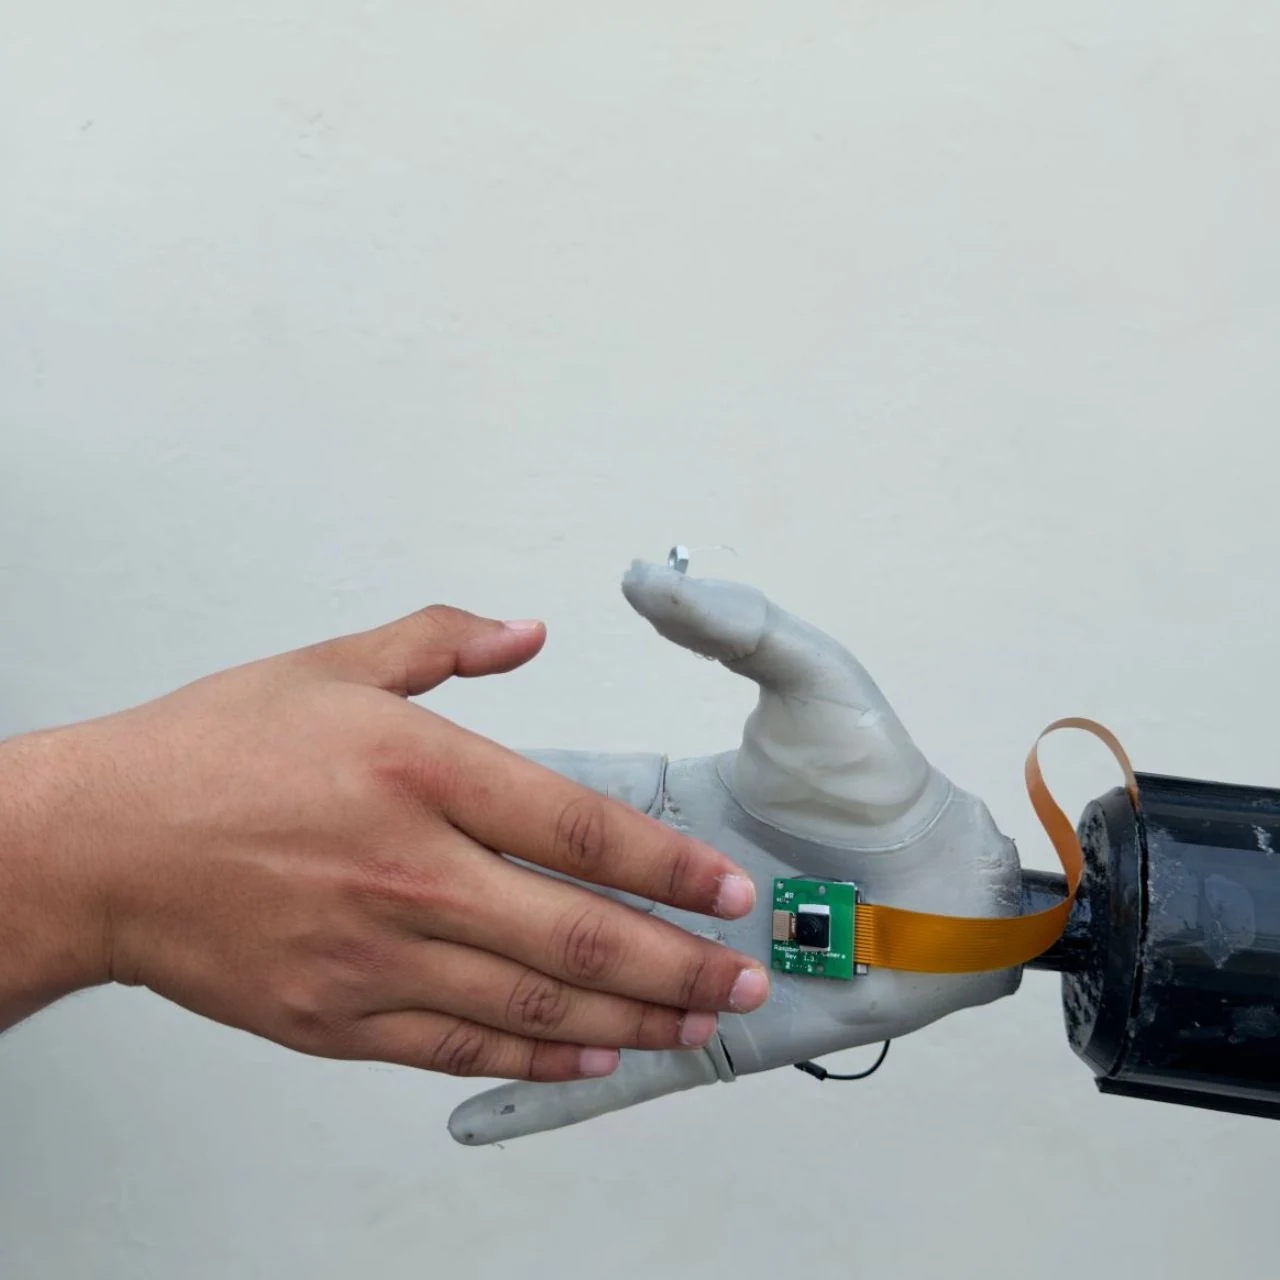
The ReFlex soft robotic hand with a palm-mounted camera, beside a human hand
FROM IDEA TO PROTOTYPE
IN FOCUSReFlex / Intelligent prosthetics
Robotics & automationEmbedded intelligenceConnected products

THE WORK, UP CLOSE

Built across disciplines.

Real project material, with the context
behind each system.

01COMPUTER VISION & AUTONOMOUS TRACKING

SKYLOCKSeeing the bigger picture.

Military-grade project

From remote control to full autonomy.

SKYLOCK is a military-grade system that brings camera feeds, computer vision and control hardware together. It was developed in two phases: first for remote operation, then for fully autonomous drone tracking.

  • Computer vision
  • Autonomous tracking
  • Remote operation
  • Embedded systems

PHASE 1 / THE FIRST ITERATION

SKYLOCK v1

The first system paired physical hardware with a custom operator application, built so SKYLOCK could be controlled remotely. These development materials document that prototype.
02WEARABLE AI & ACCESSIBILITY

SceneScribeA clearer sense of the world.

Assistive technology prototype

VISION-LANGUAGE MODELS + SMARTCANE

Useful context.
Less cognitive load.

SceneScribe is designed to support independence and mobility for people with visual impairments. Wearable vision-language assistance and a SmartCane bring environmental context into an experience centered on spoken interaction.

  1. 01
    Capture the surroundings

    Wearable vision supports hands-free scene awareness.

  2. 02
    Interpret what matters

    Specialized agents focus descriptions on the user’s request.

  3. 03
    Keep the response useful

    Relevant audio feedback aims to reduce unnecessary information.

  • Vision-language models
  • Multi-agent workflow
  • Wearable hardware

03HUMAN–ROBOT INTERACTION

HARPBuilt to move. Designed to engage.

Humanoid robot prototype

HUMANOID AUTONOMOUS RESPONSE PLATFORM

Interaction meets
physical intelligence.

HARP brings autonomous and remote-controlled operation into a humanoid platform. Face tracking, responsive head movement and conversational interaction help it engage with people at eye level.

  1. 01
    Navigate with flexibility

    Autonomous navigation on a predefined map, with remote control when needed.

  2. 02
    Engage naturally

    Face tracking, expressive displays and responsive conversation.

  3. 03
    Build for different settings

    A modular platform for reception, guidance and human–robot interaction research.

  • Autonomous navigation
  • Face tracking
  • Modular robotics

04ASSISTIVE ROBOTICS & EMBEDDED AI

ReFlexIntent, translated into movement.

Research prototype
ReFlex flexible prosthetic hand showing its integrated camera and physical prototype
Physical prototype · Project team photography

INTELLIGENT PROSTHETIC HAND

A human problem.
An integrated response.

ReFlex explores how a prosthetic hand can respond to both its wearer and the object in front of it. The research prototype combines a flexible, tendon-driven hand with muscle-signal sensing, embedded vision and feedback from its motors.

  1. 01
    Sense intent

    An EMG sensor reads forearm muscle activity to initiate movement.

  2. 02
    Understand the object

    A palm-mounted camera and trained vision model inform grip selection, including pinch and tripod grips.

  3. 03
    Respond with feedback

    Encoder feedback tracks finger movement and supports controlled stopping.

  • Raspberry Pi 5
  • TensorFlow Lite
  • Sensor fusion

THE ENGINEERING CHALLENGE

Bring intention, perception
and movement into one system.

The challenge was to coordinate several kinds of input while building a hand with a flexible, human-like form. ReFlex connects the mechanical design, embedded electronics and control software in a working laboratory prototype.

01 / FABRICATION
Start with a softer structure.

TPU 95A 3D-printed fingers use string-driven actuation. A custom forearm sleeve houses the assembly, bringing the wearable structure and the hand together.

Fusion 360 · SolidWorks · Prusa Slicer
02 / EMBEDDED VISION
Choose a grip from visual context.

A custom-trained MobileNetV2 model runs through TensorFlow Lite on a Raspberry Pi 5. The palm camera supplies the object view used to select a suitable grip.

Pi Camera · MobileNetV2 · TensorFlow Lite
03 / CONTROL
Keep sensing and motion connected.

The control pipeline combines EMG input, camera data and encoder feedback. Motor commands and position feedback coordinate the fingers through the grip cycle.

Python · C/C++ · Encoder-based actuation
RESEARCH / ICRAI 2024
Two conference papers.

Research explored soft robotic fabrication with embedded vision, and a lightweight CNN for grasp classification.

RECOGNITION / COMPECC
Appreciation Award.

Recognition for the intelligent prosthetic-hand project and its integrated engineering approach.

05CONNECTED AGRICULTURE

Bovine SenseA small device. A connected vision.

Product prototype
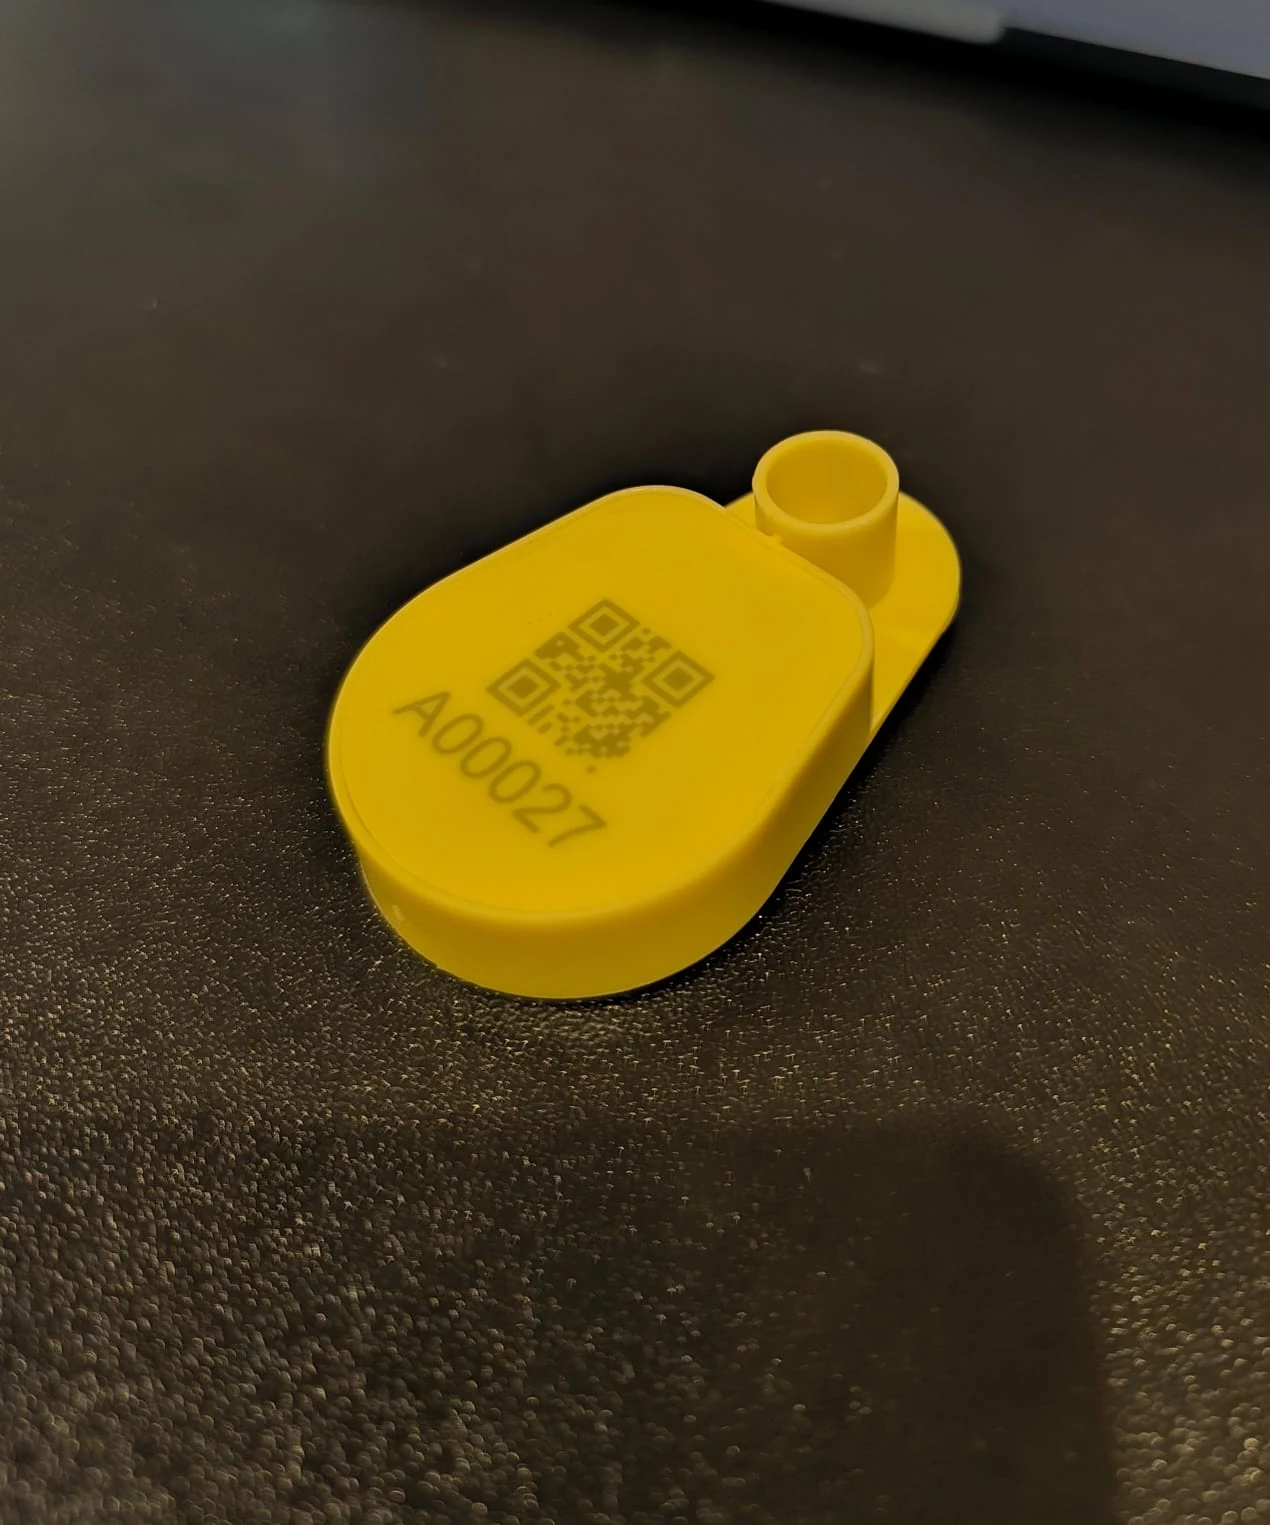
Physical yellow Bovine Sense ear-tag prototype marked A00027 with a QR code
THE PHYSICAL PROTOTYPEEAR TAG / A00027

LIVESTOCK CARE, CONNECTED

From animal identification
to a clearer herd picture.

Bovine Sense brings a physical ear-tag prototype together with a connected-care product concept, centered on temperature monitoring, animal identification and mobile access to herd information.

01 / MONITOR
Temperature awareness

Designed around timely health information.

02 / IDENTIFY
Individual animal identity

A distinct tag for each animal.

03 / CONNECT
Information on the go

A mobile view of herd data and alerts.

AUTONOMY IN THE PHYSICAL WORLD

Systems that move with purpose.

From indoor delivery
to competition robotics.

06AUTONOMOUS DELIVERY

Auto VendiFrom a mobile request to a physical delivery.

Delivery robot prototype

SOFTWARE MEETS MOBILITY

A connected delivery experience.

Auto Vendi brings mobile ordering, indoor navigation and a cargo compartment into one robotic delivery prototype. The demonstration follows the interaction from the phone interface to the robot’s arrival and compartment access.

  1. 01
    Request a delivery

    A mobile interface presents ordering and destination selection.

  2. 02
    Move through the environment

    The mobile platform travels through an indoor corridor.

  3. 03
    Complete the handoff

    The cargo lid opens to make the delivery accessible.

  • Mobile interface
  • Indoor navigation
  • Robotic delivery

07AUTONOMOUS MOBILE ROBOTICS

Tree-planting robotMechanical design. Intelligent movement.

Sept 2023 – April 2024

NATIONAL ENGINEERING ROBOTICS CONTEST

Best Engineering Design Award

Selected from 22 teams

TREE PLANTING AUTONOMOUS ROBOT

Navigate, position, plant.

A mobile robot developed for autonomous tree planting in a competition setting. A purpose-built mechanism, selectable grid maps and responsive line following coordinate movement and payload placement.

  1. 01
    Plan on a grid

    Dynamic, grid-based map selection supports navigation through the course.

  2. 02
    Follow the route

    A QTR-8A sensor array and PID control keep the robot responsive to the marked path.

  3. 03
    Handle the planting task

    The mechanical assembly positions the payload in the simulated planting arena.

  • Mechanical design
  • Grid navigation
  • QTR-8A
  • PID control

Engineered for the course.

The photographs and film show the robot operating with tree-marked blocks on the NERC arena. This competition prototype brought navigation, sensing and the placement mechanism together in a practical demonstration.

LET’S GET INTO THE DETAILS

Good engineering
stands up to a closer look.

Let’s walk through the work, discuss the engineering decisions, and connect the relevant experience to your project.

Start a conversation
Back to top